Robotics · Machine vision · Industrial AI
Robots that learn in simulation and work on the factory floor.
We design robotic cells, train their vision and motion in digital twins and bring them into production: from the first sketch to commissioning.
Simulation first
Every cell runs virtual shifts before it meets real hardware.
Data by design
Rendered and generated images, checked against real footage, train our models.
Edge-ready
Models run on compact computers on board, right next to the machine.
Built by machine builders
We design, wire and commission the hardware ourselves.
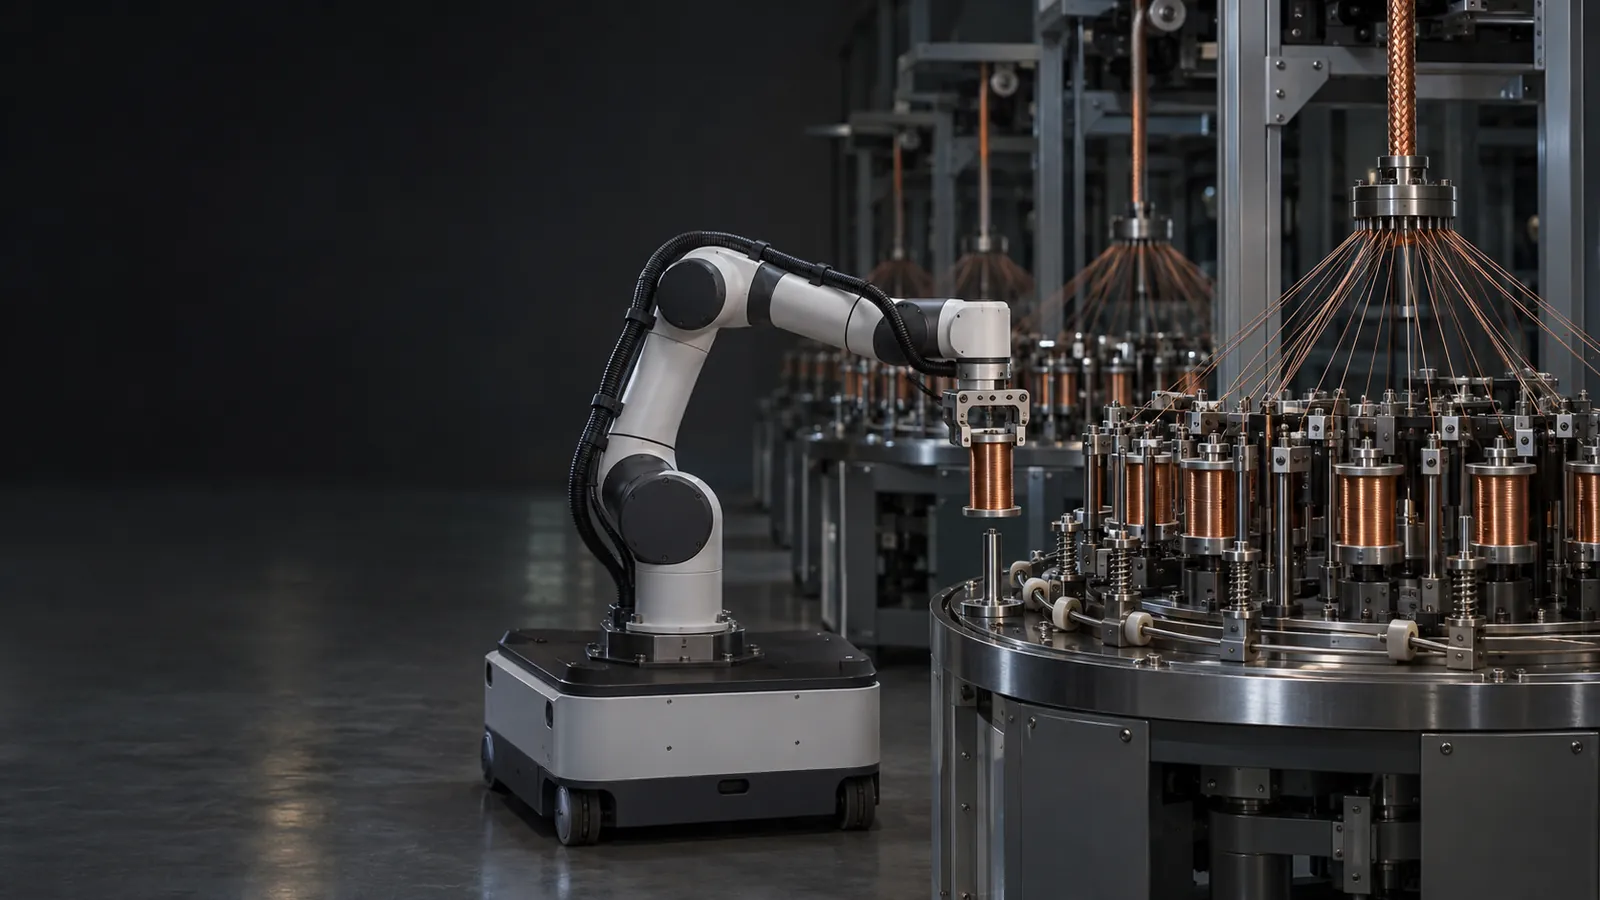
Flagship project
Bobbins that change themselves.
Braiding and rope machines stop whenever a bobbin runs empty. Our cell finds the empty bobbin, brings a full one and swaps it while the machine waits in its change position.
- Detects low bobbins before the wire runs out
- A mobile robot supplies full bobbins from the winder
- A robot arm with vision swaps bobbins at the carrier
What we do
From the machine to the model.
One team for mechanics, controls, simulation and AI, from concept to commissioning.
Robotic cells
Cobots on mobile platforms, gantries and fixed cells for loading, handling and palletising.
Learn moreDigital twins
Physics-based twins of cells and halls. We test layouts, motion and cycle times virtually, then confirm them on the real cell.
Learn moreRobot learning
Robot skills learned from scripted experts and demonstrations in simulation, then transferred to the real arm.
Learn moreMachine vision
Detection, segmentation and 6D pose, trained on synthetic images and automatically labelled real footage.
Learn more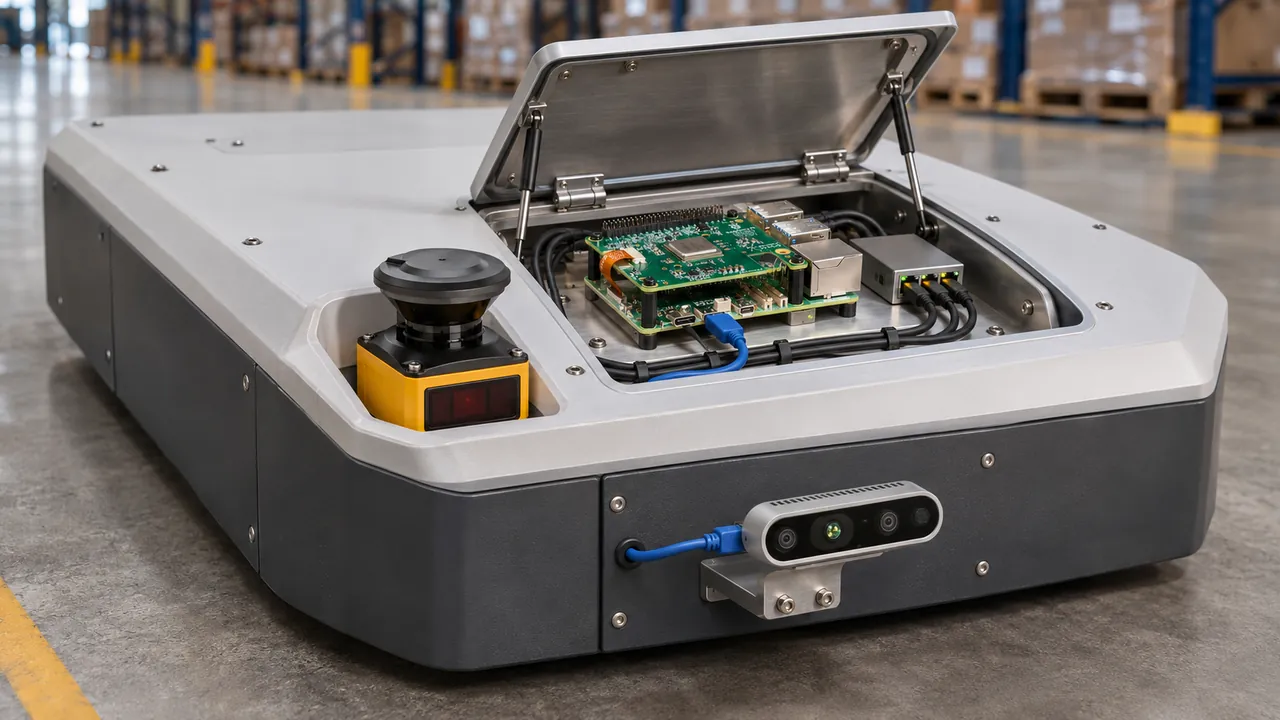
Mobile robots & edge AI
Cameras and laser scanners fused in real time on compact edge accelerators, on board the robot.
Learn more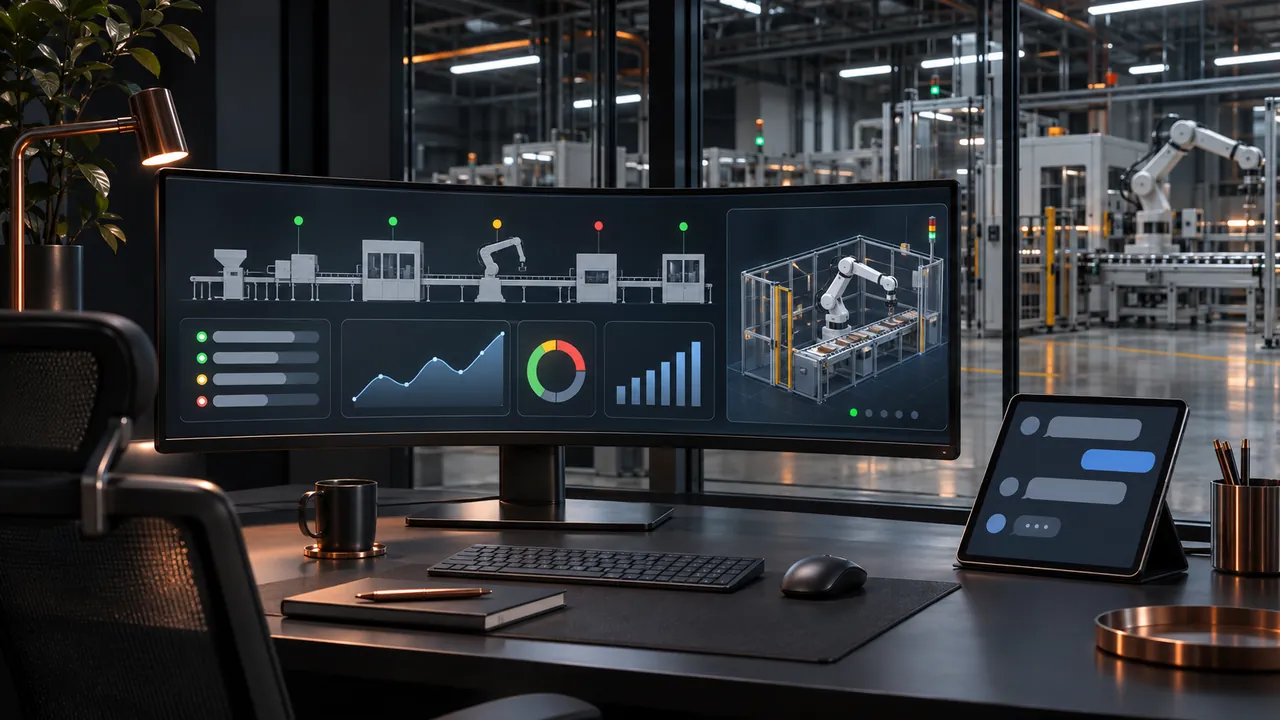
Software & AI agents
Web platforms, dashboards and AI assistants that connect machines, data and people.
Learn moreHow we work
Simulate first. Then build.
- 01
Understand
We measure the process on site: parts, cycle times, shifts and the people around the machine.
- 02
Model
CAD and physics models of the machine, the robot and the hall become one digital twin.
- 03
Train
Vision models and robot skills learn in simulation, on synthetic and generated data.
- 04
Validate
We record real tests, check the annotations and feed relevant edge cases back into the twin.
- 05
Deploy
We commission the cell, connect it to the machine control and keep it improving.
In motion
What runs on our screens and our shop floor.
Vacuum gripper on soft sacks, simulated with real physics
A learned policy assembling parts in simulation
Depth view of parts for grasp planning
Simulation-ready robot built from CAD
Cord machine on the shop floor
Where we work
Industries with heavy, repetitive handling.
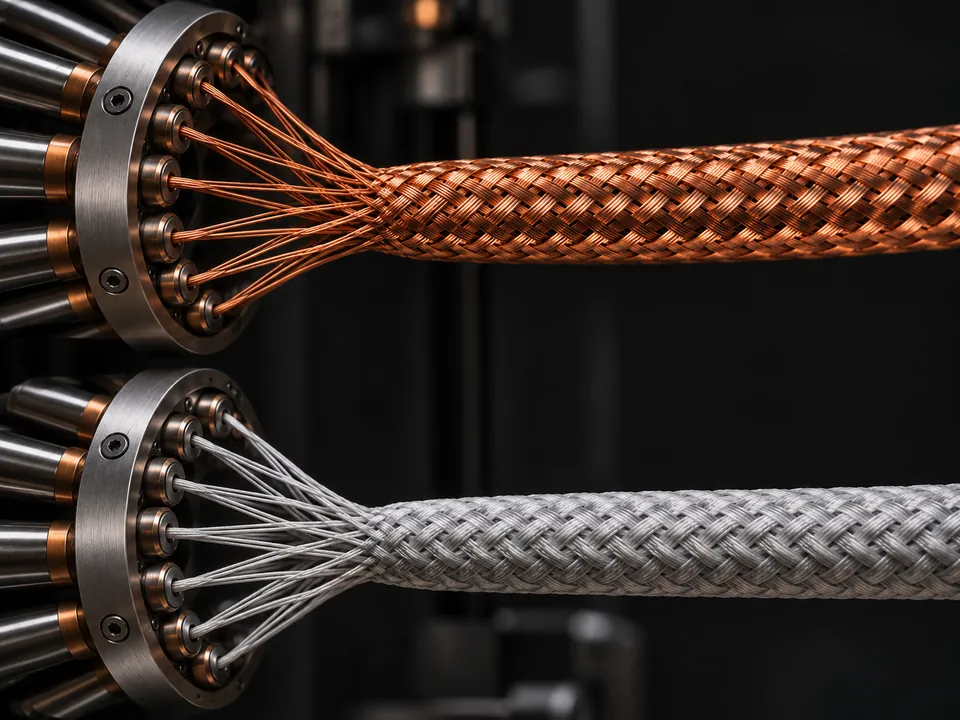
Textile, wire & cable
Braiding, stranding, winding and knitting lines.
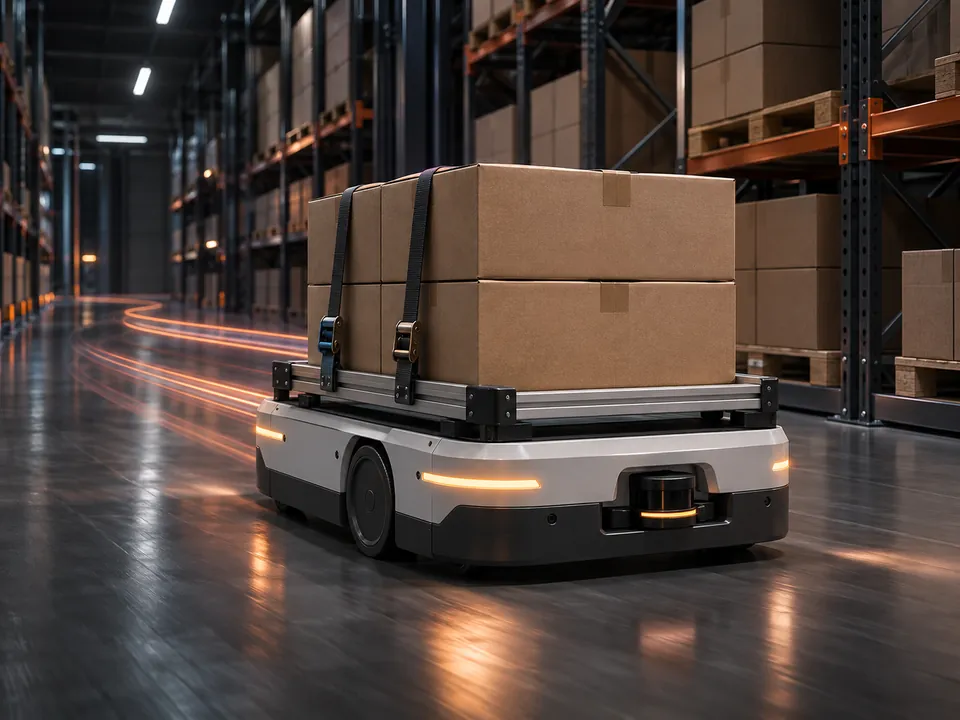
Intralogistics
Mobile robots that move loads safely through busy halls.
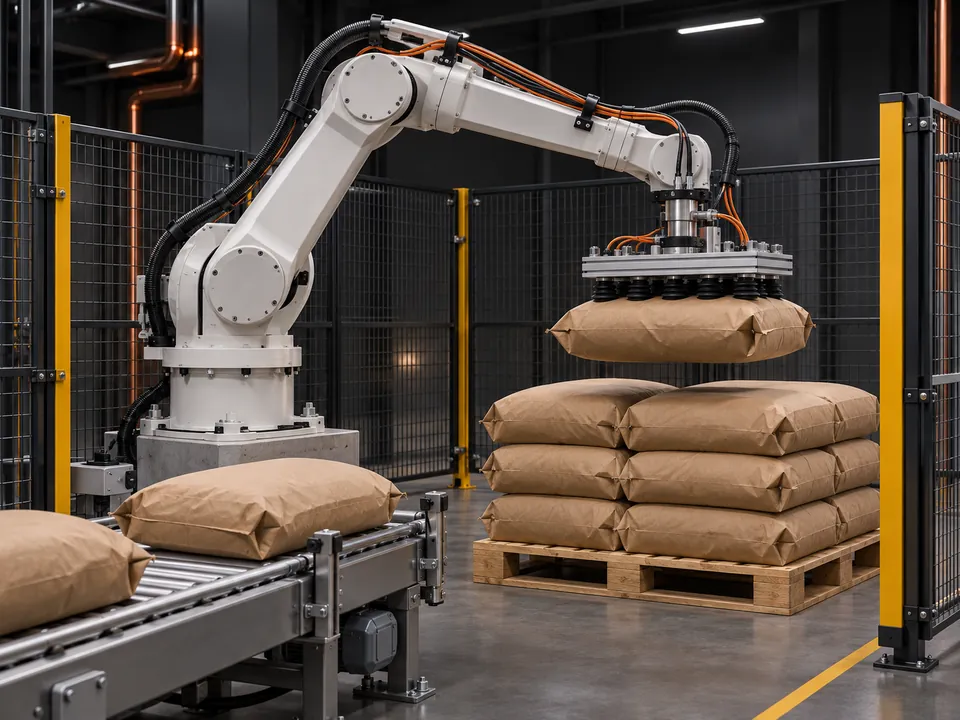
Packaging & bulk goods
Sack and carton handling, palletising cells.
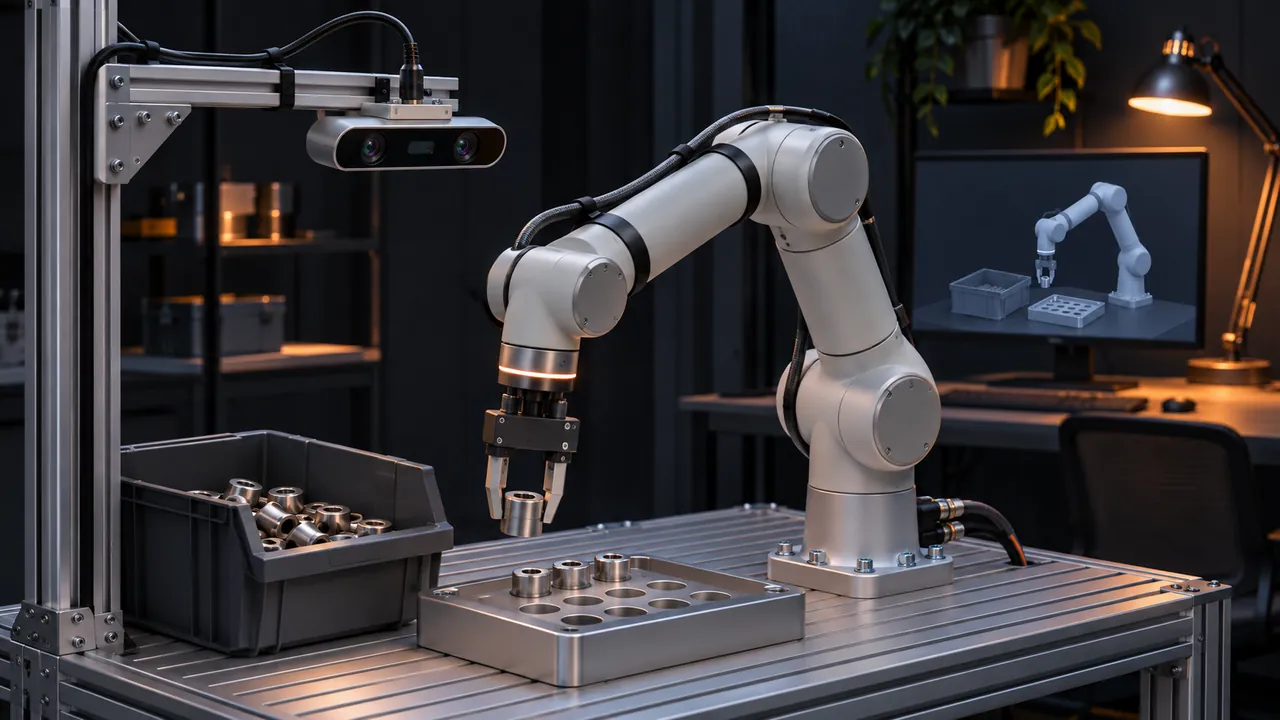
Machining & assembly
Part picking, inspection and machine tending.
Technology
Our everyday toolbox.
- ROS 2
- Physics simulation
- Digital twins
- Vision-language models
- Diffusion models
- 6D pose estimation
- Sensor fusion
- Edge accelerators
- PLC & fieldbus
- CAD & motion studies
- Docker & Kubernetes
- Full-stack web
Have a process that should run by itself?
Tell us about your machine, your parts and your shifts. We answer with a first concept.